 |
onboardapi
9.10.0
by Rheinmetall
|
|
onboardapi
9.10.0
by Rheinmetall
|
Public Member Functions | |
| virtual | ~IService () |
| virtual void | ConfigHelpRateInputSource (std::string const &ClientId) |
| virtual void | CmdLeadOn (M_Common::ObjectIdOptionalType const &ObjId) |
| virtual void | CmdApdAbsolute (M_Common::SphericalPositionType const &Pos) |
| virtual void | CmdApdByStep (int32_t StepsAzimuth, int32_t StepsElevation) |
| virtual void | CmdApdByCenterOffset (M_Common::SphericalPositionType const &Pos) |
| virtual void | ConfigAutoLeadOn (bool Enable) |
| virtual void | NotifyMountTrackingState (M_VideoTracker::MountTrackingState::Type State) |
| virtual void | NotifyHelpRate (M_Common::AngularVelocityType const &HelpRate) |
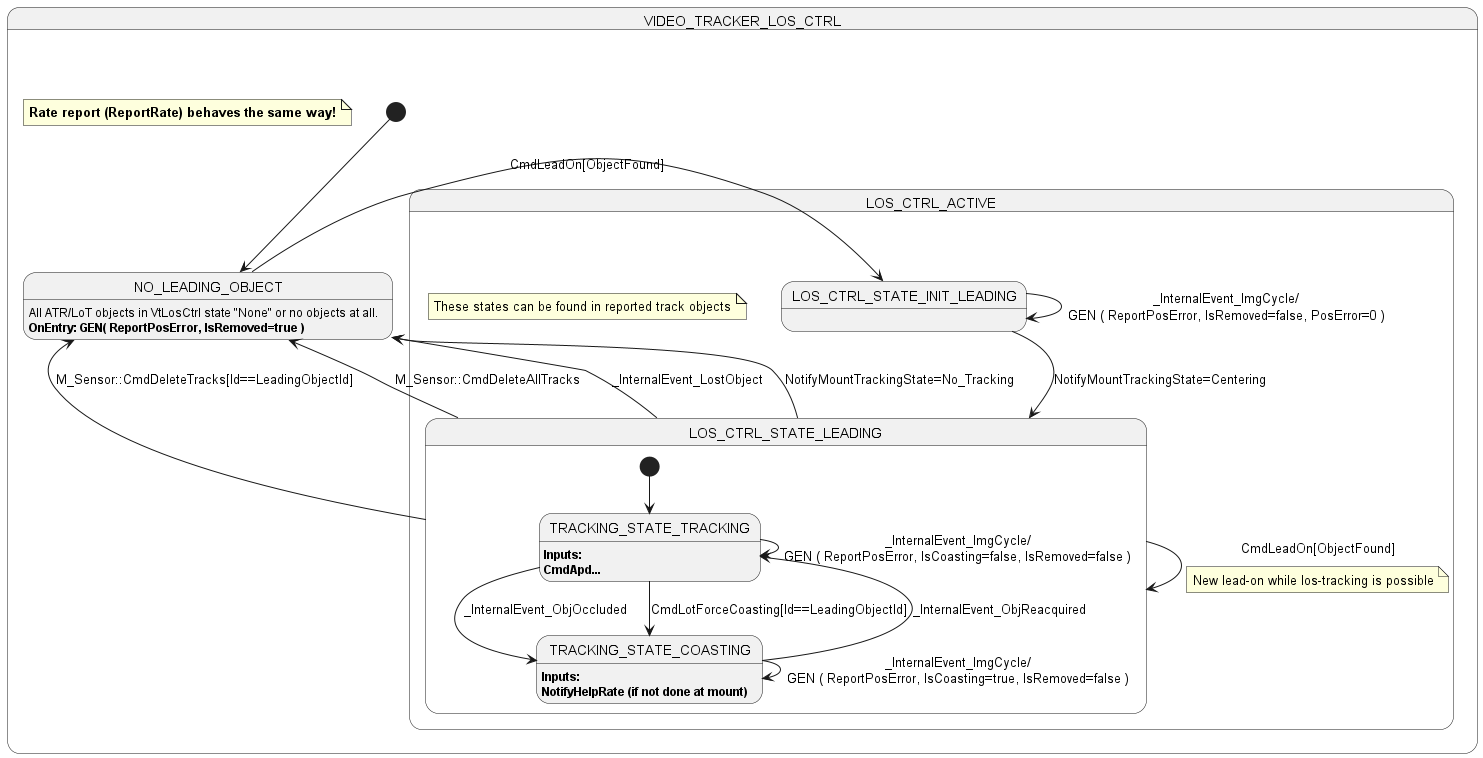
Line-of-Sight Control (LOS) Service interface. Contains operations that a client can command the Line-of-Sight Control (LOS) Service to perform.
|
virtual |
|
virtual |
Set offset between aligned image centre and object centre (Aim Point Designation - APD) by selecting a position in the image.
The current difference between leading object centre and selected position is applied as aim point offset.
Note: APD is applied to the current leading object only and is not persistent. It is reset to zero at every lead-on.
| Pos | Position in camera field of view w.r.t. image centre. |
|
virtual |
Set offset between aligned image centre and object centre (Aim Point Designation - APD).
Note: APD is applied to current leading object only and is not persistent. It is reset to zero at every lead-on.
| Pos | Offset from object centre. |
|
virtual |
Increment/decrement current offset between aligned image centre and object centre (Aim Point Designation - APD).
Note: APD is applied to current leading object only and is not persistent. It is reset to zero at every lead-on.
Note: One step corresponds to the angular extent of one pixel of the current VideoTracker input video.
| StepsAzimuth | The number of steps to increase/decrease in azimuth direction. |
| StepsElevation | The number of steps to increase/decrease in elevation direction. |
|
virtual |
Lead-on an object.
| ObjId | Identifies an existing currently tracked object. Note: If not present then the VideoTracker should initiate a lead-on at the aligned image centre. Note: If ObjId is "Selected", a lead-on on the currently selected object (if available) is initiated. Note: If ObjId is "SelectedOrCenter", a leaded-on on the currently selected object (if available) is initiated. Which object will be leaded-on is described by M_VideoTracker::VtObjectType::IsSelected flag. |
|
virtual |
Set automatic Lock-On and Lead-On enabled. When enabled, a lead-on the current or first upcoming selected ATR object is initiated.
| Enable | Enable or disable (True = Enable, False = Disable). |
|
virtual |
Configure the client source for help rate input.
Note: The "NotifyHelpRate" calls should only be handled from this configured client.
| ClientId | Name of client to accept data inputs from. Empty string indicates data shall be accepted from all clients. |
|
virtual |
Set help rate to influence rate that VideoTracker generates. E.g. to support the VideoTracker while coasting.
| HelpRate | Angular rate [deg/s]. |
|
virtual |
Inform LOS-Control about the state of mount regarding being controlled by VideoTracker. This information is needed to close the LosCtrl loop.
| State | Tracking state of a Mount. |
 1.9.1