 |
onboardapi
9.10.0
by Rheinmetall
|
|
onboardapi
9.10.0
by Rheinmetall
|
Public Member Functions | |
| virtual | ~IClient () |
| virtual void | ReportCoordinateFrameSettings (M_CoordinateFrame::CoordinateFrameSettingsType const &Settings) |
| virtual void | ReportCoordinateFrameStatus (M_CoordinateFrame::CoordinateFrameStatusType const &Status, bool IsRemoved) |
| virtual void | ReportCoordinateTransformations (std::string const &KeyId, M_Common::CoordinateTransformationListType const &TransformationList, bool IsRemoved) |
| virtual void | ReportPositions (std::string const &KeyId, M_Common::PositionListType const &PositionList, bool IsRemoved) |
| virtual void | ReportAttitudes (std::string const &KeyId, M_Common::AttitudeListType const &AttitudeList, bool IsRemoved) |
| virtual void | ReportLinearVelocities (std::string const &KeyId, M_Common::LinearVelocityListType const &LinearVelocityList, bool IsRemoved) |
| virtual void | ReportAngularVelocities (std::string const &KeyId, M_Common::AngularVelocityListType const &AngularVelocityList, bool IsRemoved) |
| virtual void | ReportLinearAccelerations (std::string const &KeyId, M_Common::LinearAccelerationListType const &LinearAccelerationList, bool IsRemoved) |
| virtual void | ReportAngularAccelerations (std::string const &KeyId, M_Common::AngularAccelerationListType const &AngularAccelerationList, bool IsRemoved) |
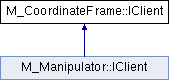
Coordinate frame client interface. Contains callback operations from the coordinate frame service to the client.
|
virtual |
Reimplemented in M_Manipulator::IClient.
|
virtual |
Report angular acceleration in different coordinate frames.
| KeyId | Identifies the moving entity associated with the angular acceleration. Note: This may also be the service name of another network participant. In this case, this associates the data with the device to which the service name belongs. |
| AngularAccelerationList | Angular acceleration in different coordinate frames. |
| IsRemoved | Indicates if the status is no longer available. Note: This will always be set to true when a service has been shut down. After this has been set to true, the status will no longer be available to late joiners. |
|
virtual |
Report angular velocity in different coordinate frames.
| KeyId | Identifies the moving entity associated with the angular velocity. Note: This may also be the service name of another network participant. In this case, this associates the data with the device to which the service name belongs. |
| AngularVelocityList | Angular velocity in different coordinate frames. |
| IsRemoved | Indicates if the status is no longer available. Note: This will always be set to true when a service has been shut down. After this has been set to true, the status will no longer be available to late joiners. |
|
virtual |
Report attitude in different coordinate frames.
| KeyId | Identifies the moving entity associated with the attitude. Note: This may also be the service name of another network participant. In this case, this associates the data with the device to which the service name belongs. |
| AttitudeList | Attitude in different coordinate frames. |
| IsRemoved | Indicates if the status is no longer available. Note: This will always be set to true when a service has been shut down. After this has been set to true, the status will no longer be available to late joiners. |
|
virtual |
Report coordinate frame static settings.
| Settings | Coordinate frame settings. |
|
virtual |
Report current coordinate frame status.
| Status | CoordinateFrame status data. |
| IsRemoved | Indicates if the status is no longer available. Note: This will always be set to true when a service has been shut down. After this has been set to true, the status will no longer be available to late joiners. |
|
virtual |
Report coordinate transformation in different coordinate system.
| KeyId | Identifies the moving entity associated with the coordinate transformation. Note: This may also be the service name of another network participant. In this case, this associates the data with the device to which the service name belongs. |
| TransformationList | Transformation specification in different coordinate frames. |
| IsRemoved | Indicates if the status is no longer available. Note: This will always be set to true when a service has been shut down. After this has been set to true, the status will no longer be available to late joiners. |
|
virtual |
Report linear acceleration in different coordinate frames.
| KeyId | Identifies the moving entity associated with the linear acceleration. Note: This may also be the service name of another network participant. In this case, this associates the data with the device to which the service name belongs. |
| LinearAccelerationList | Linear acceleration in different coordinate frames. |
| IsRemoved | Indicates if the status is no longer available. Note: This will always be set to true when a service has been shut down. After this has been set to true, the status will no longer be available to late joiners. |
|
virtual |
Report linear velocity in different coordinate frames.
| KeyId | Identifies the moving entity associated with the linear velocity. Note: This may also be the service name of another network participant. In this case, this associates the data with the device to which the service name belongs. |
| LinearVelocityList | Linear velocity in different coordinate frames. |
| IsRemoved | Indicates if the status is no longer available. Note: This will always be set to true when a service has been shut down. After this has been set to true, the status will no longer be available to late joiners. |
|
virtual |
Report position in different coordinate frames.
| KeyId | Identifies the moving entity associated with the position. Note: This may also be the service name of another network participant. In this case, this associates the data with the device to which the service name belongs. |
| PositionList | Position in different coordinate frames. |
| IsRemoved | Indicates if the status is no longer available. Note: This will always be set to true when a service has been shut down. After this has been set to true, the status will no longer be available to late joiners. |
 1.9.1