 |
onboardapi
9.10.0
by Rheinmetall
|
|
onboardapi
9.10.0
by Rheinmetall
|
Public Member Functions | |
| virtual | ~IService () |
| virtual void | NotifyCoordinateTransformation (std::string const &KeyId, M_Common::CoordinateTransformationType const &Transformation) |
| virtual void | NotifyPosition (std::string const &KeyId, M_Common::PositionType const &Position) |
| virtual void | NotifyAttitude (std::string const &KeyId, M_Common::AttitudeType const &Attitude) |
| virtual void | NotifyLinearVelocity (std::string const &KeyId, M_Common::LinearVelocityType const &LinearVelocity) |
| virtual void | NotifyAngularVelocity (std::string const &KeyId, M_Common::AngularVelocityType const &AngularVelocity) |
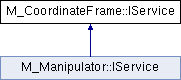
Coordinate frame service interface. Contains operations that a client can command the coordinate frame service to perform.
|
virtual |
Reimplemented in M_Manipulator::IService.
|
virtual |
Notify to set angular velocity.
| KeyId | Identifies the coordinate frame or axis to move. Note: This may also be the service name of another network participant. In this case, this relates the data to the device to which the service name belongs. |
| AngularVelocity | Angular velocity. |
|
virtual |
Notify to set attitude.
| KeyId | Identifies the coordinate frame or axis to move. Note: This may also be the service name of another network participant. In this case, this relates the data to the device to which the service name belongs. |
| Attitude | Attitude. |
|
virtual |
Notify to set coordinate transformation.
| KeyId | Identifies the coordinate frame or axis to move. Note: This may also be the service name of another network participant. In this case, this relates the data to the device to which the service name belongs. |
| Transformation | Transformation specification. |
|
virtual |
Notify to set linear velocity.
| KeyId | Identifies the coordinate frame or axis to move. Note: This may also be the service name of another network participant. In this case, this relates the data to the device to which the service name belongs. |
| LinearVelocity | Linear velocity. |
|
virtual |
Notify to set position.
| KeyId | Identifies the coordinate frame or axis to move. Note: This may also be the service name of another network participant. In this case, this relates the data to the device to which the service name belongs. |
| Position | Position. |
 1.9.1