 |
onboardapi
9.10.0
by Rheinmetall
|
|
onboardapi
9.10.0
by Rheinmetall
|
Public Member Functions | |
| virtual | ~IService () |
| virtual void | CmdMultiFireLaser (bool IsActivated) |
| virtual void | CmdSingleFireLaser () |
| Cmd to fire a single shot with the laser. More... | |
| virtual void | ConfigSetFirstOrLastMeasurement (M_LaserRangeFinder::FirstOrLast::Type StrongestMeasurement) |
| virtual void | ConfigSetUserRange (M_Common::DistanceMetersOptionalType const &MinimumRange, M_Common::DistanceMetersOptionalType const &MaximumRange) |
| virtual void | ConfigInhibitLaserFiring (M_Common::ObjectIdType const &KeyComponentId, bool IsRemoved) |
| virtual void | ConfigMultiFireFrequency (M_Common::FrequencyHertzType Frequency) |
 Public Member Functions inherited from M_Sensor::IService | |
| virtual void | CmdIsSensorAlive () |
| virtual void | CmdDeleteTracks (M_Common::ObjectIdListType const &KeyIdList) |
| virtual void | CmdDeleteAllTracks () |
| virtual void | CmdDeactivateSensor (bool Deactivate) |
| virtual void | ConfigSensorCoverage (M_Common::ObjectIdType const &KeyId, M_Sensor::SensorCoverageType const &Coverage, bool IsRemoved) |
| virtual void | CmdSetPreset (M_Common::ObjectIdOptionalType const &Preset) |
| virtual void | CmdLockOnTracks (M_Common::ObjectIdListType const &KeyIdList) |
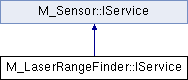
Laser Range Finder Service (LRF) interface. Contains operations that a Client can use to control the Laser Range Finder Service.
|
virtual |
Reimplemented from M_Sensor::IService.
|
virtual |
Cmd to start (true) or stop (false) the measurement of the laser in pulse mode.
| IsActivated | Indicates if pulse mode firing should be started (true) or stopped (false). True = Start firing laser False = Stop firing laser |
|
virtual |
Cmd to fire a single shot with the laser.
|
virtual |
Configure to set or remove the interlock that prevents the accidental firing of the laser.
| KeyComponentId | Identifies the component responsible for the laser firing or blocking. |
| IsRemoved | Indicates if firing should be enabled (true) or inhibited (false). True = Enable firing by removing the interlock that prevents the accidental firing of the laser. False = Inhibit firing by setting the interlock that prevents the accidental firing of the laser. |
|
virtual |
Configure the frequency of multi firing laser.
| Frequency | Frequency in Hz. |
|
virtual |
Indicate whether the first or the last range returned contains the strongest measurement.
| StrongestMeasurement | Indicate if the first range returned contains the strongest measurement or if the last measurement returned is the strongest measurement. |
|
virtual |
Sets the user defined minimum and maximum range. Note: Additionally the LRF has a minimum and maximum range that is defined by the settings.
| MinimumRange | The user defined minimum range. This range may differ from the device minimum range. Note: In case the user defined minimum range is lower than the device minimum range, the device minimum range is used. Not present indicates that the user minimum range is disabled. |
| MaximumRange | The user defined maximum range. This range may differ from the device maximum range. Note: In case the user defined maximum range is higher than the device maximum range, the device maximum range is used. Not present indicates that the user maximum range is disabled. |
 1.9.1