 |
onboardapi
9.10.0
by Rheinmetall
|
|
onboardapi
9.10.0
by Rheinmetall
|
The following interfaces are part of the library.
Client and Service classes:
Operations:
Description:
Types used by the actuation control service and client. Interfaces used by the actuation control service and client.
Client and Service classes:
Operations:
Description:
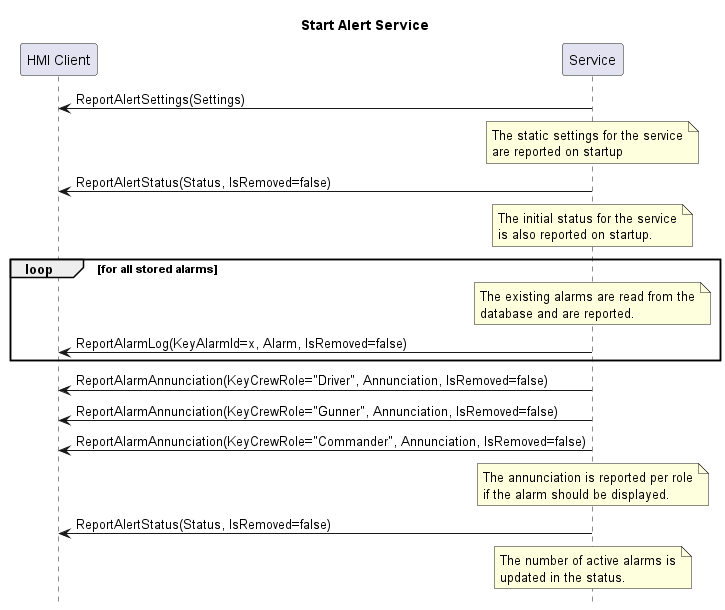
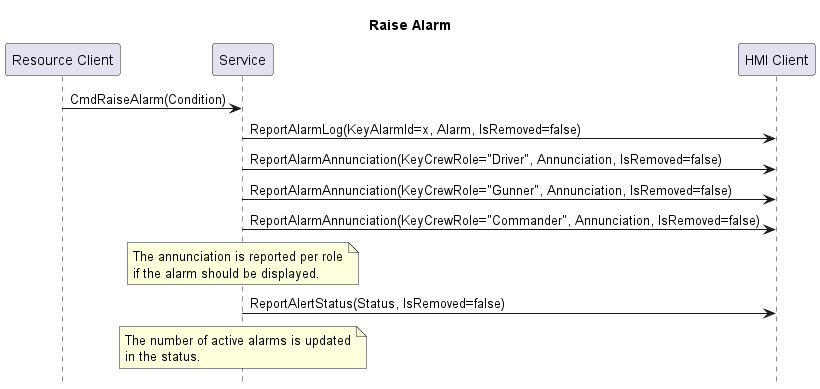
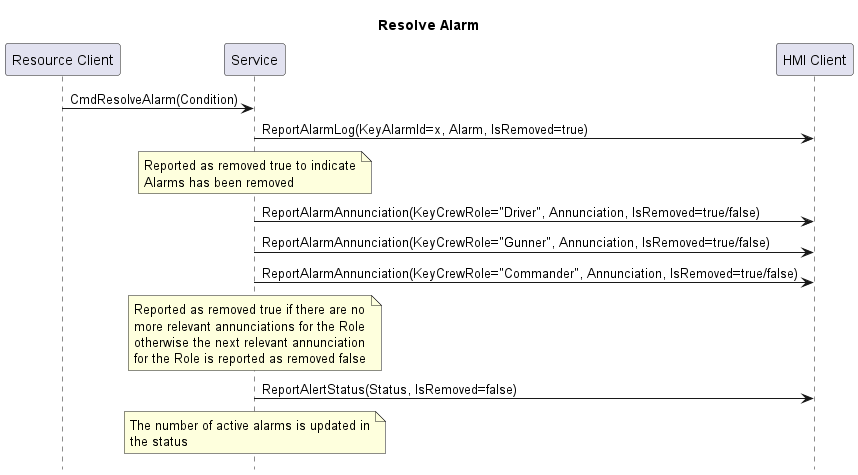
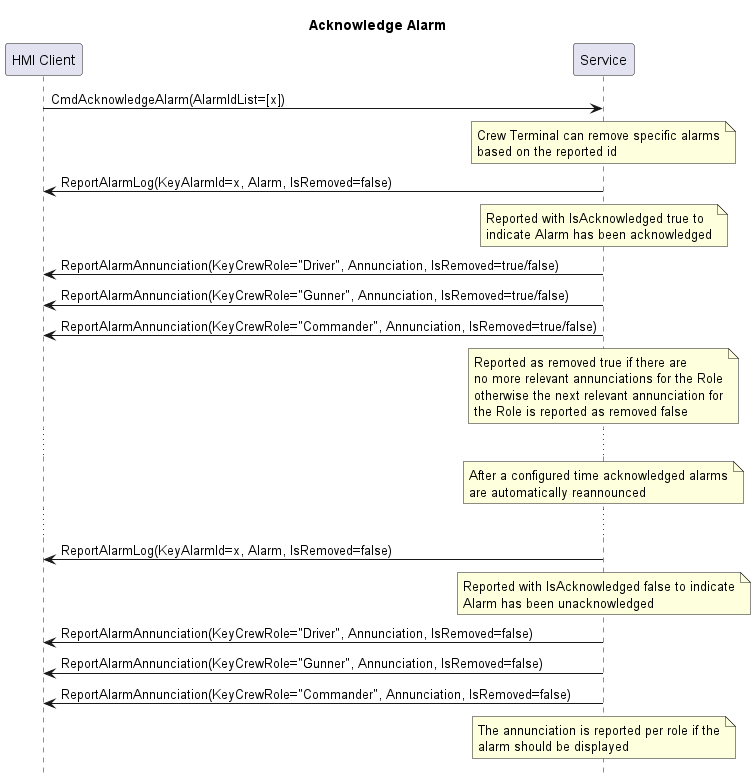
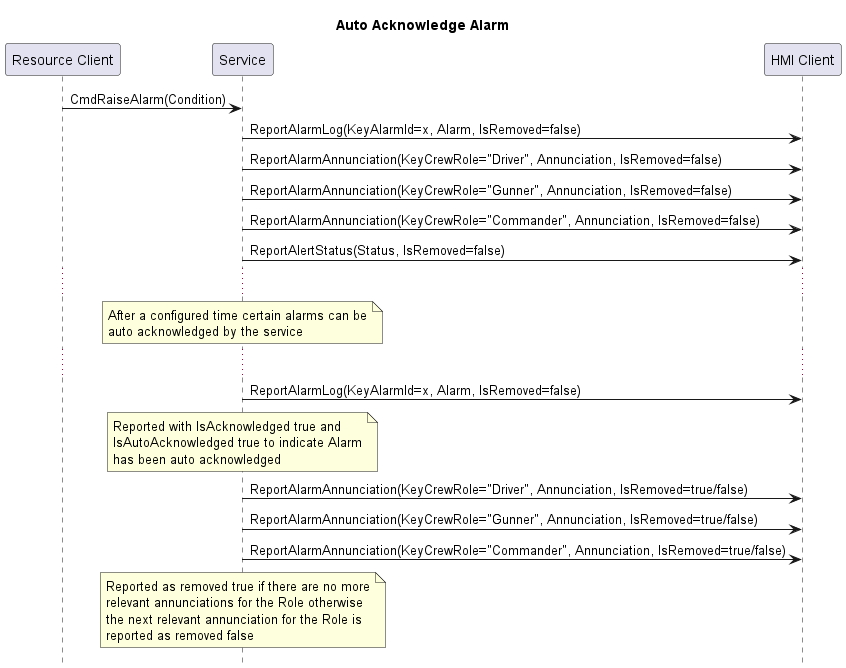
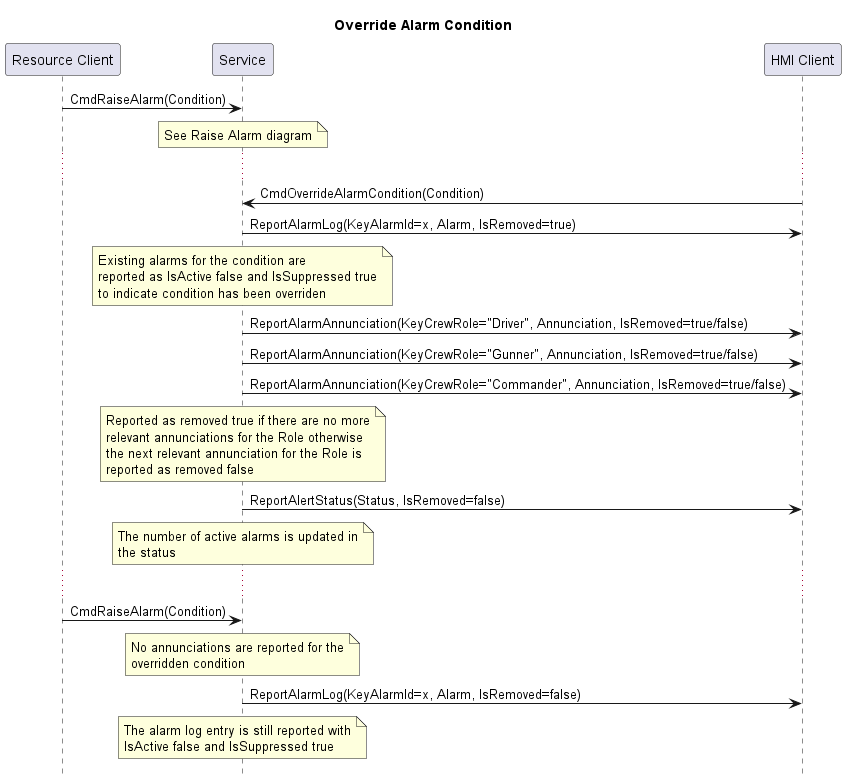
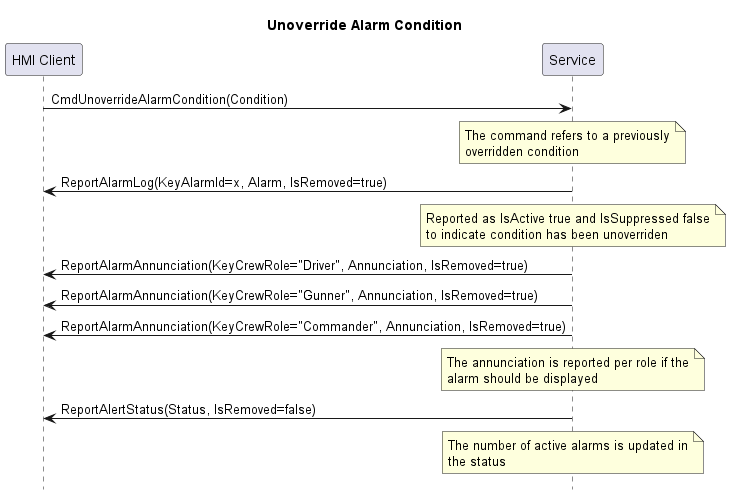
Types used by the Alert Service/Client. An Alert service generates Alerts (Alarms and Threat Alerts) from resource clients. It manages the lifetime of these generates Alerts.
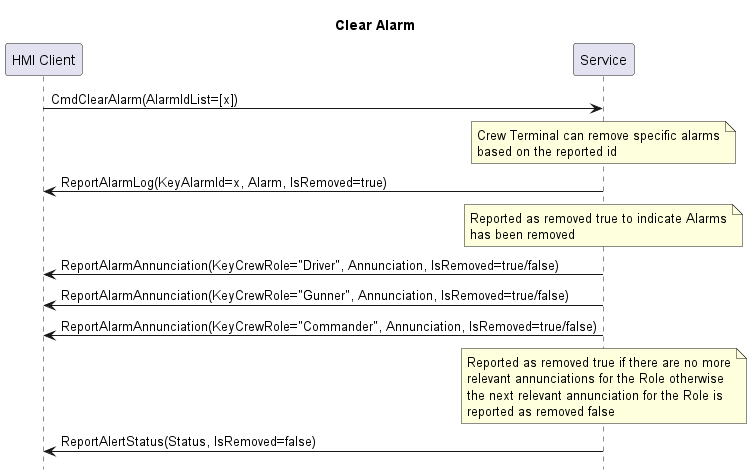
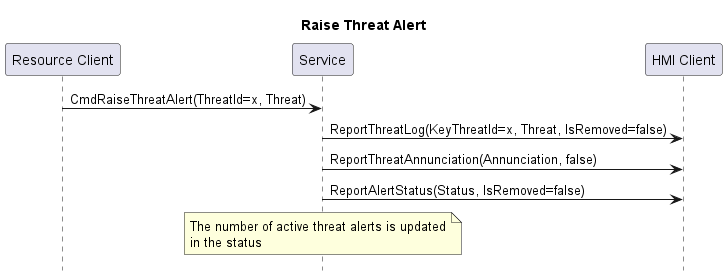
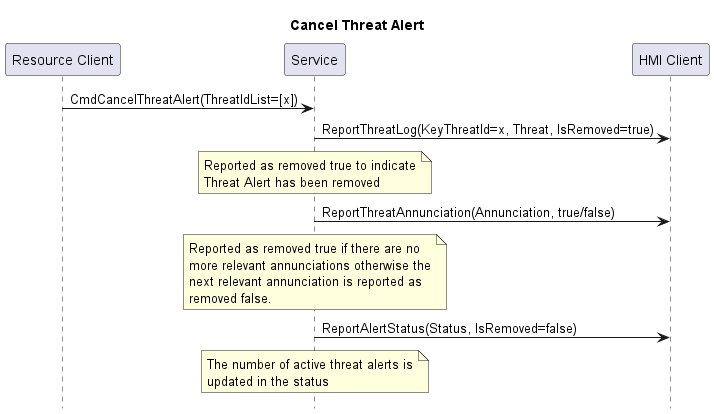
Client and Service classes:
Operations:
Description:
Types used by the alignment service and client. Interfaces used by the coordinate frame service and client. The service can be used to manage positions, attitudes and motion across different reference frames. It also enables aligning a component's line of sight with a target.
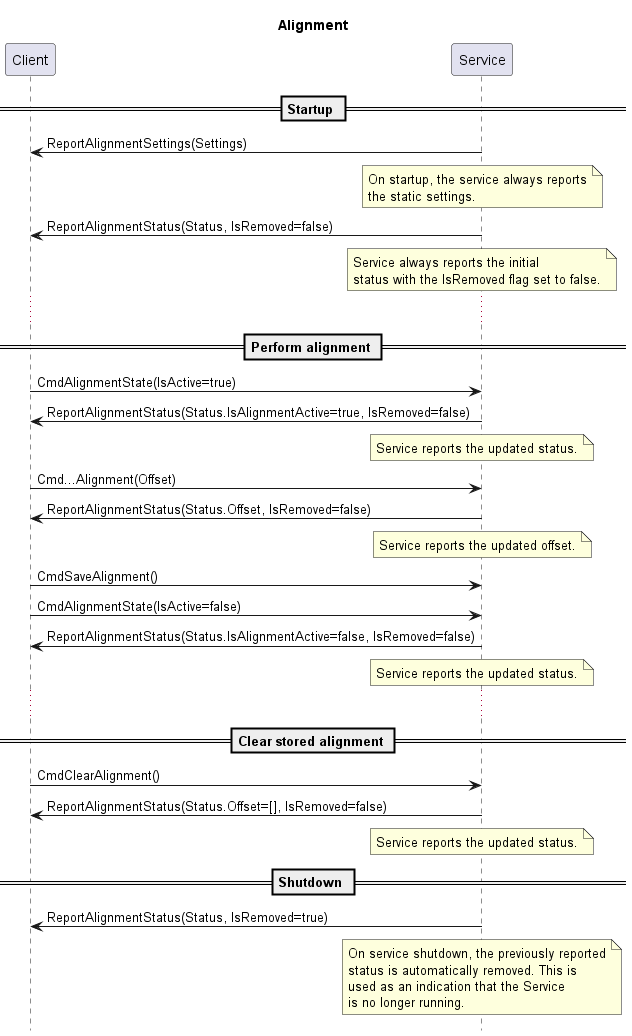
Client and Service classes:
Operations:
Description:
Types used by the analogue input/output service and client. An analogue input/output interface is used to set or retrieve analogue signals in/from devices.
Client and Service classes:
Operations:
Description:
Types used by the Auth Service and Client. A auth service.
Client and Service classes:
Operations:
Description:
Types used by the BITE Service and Client. A BITE (Built-In Test Equipment) service is used to perform PBIT, CBIT and IBIT and report results and failures.
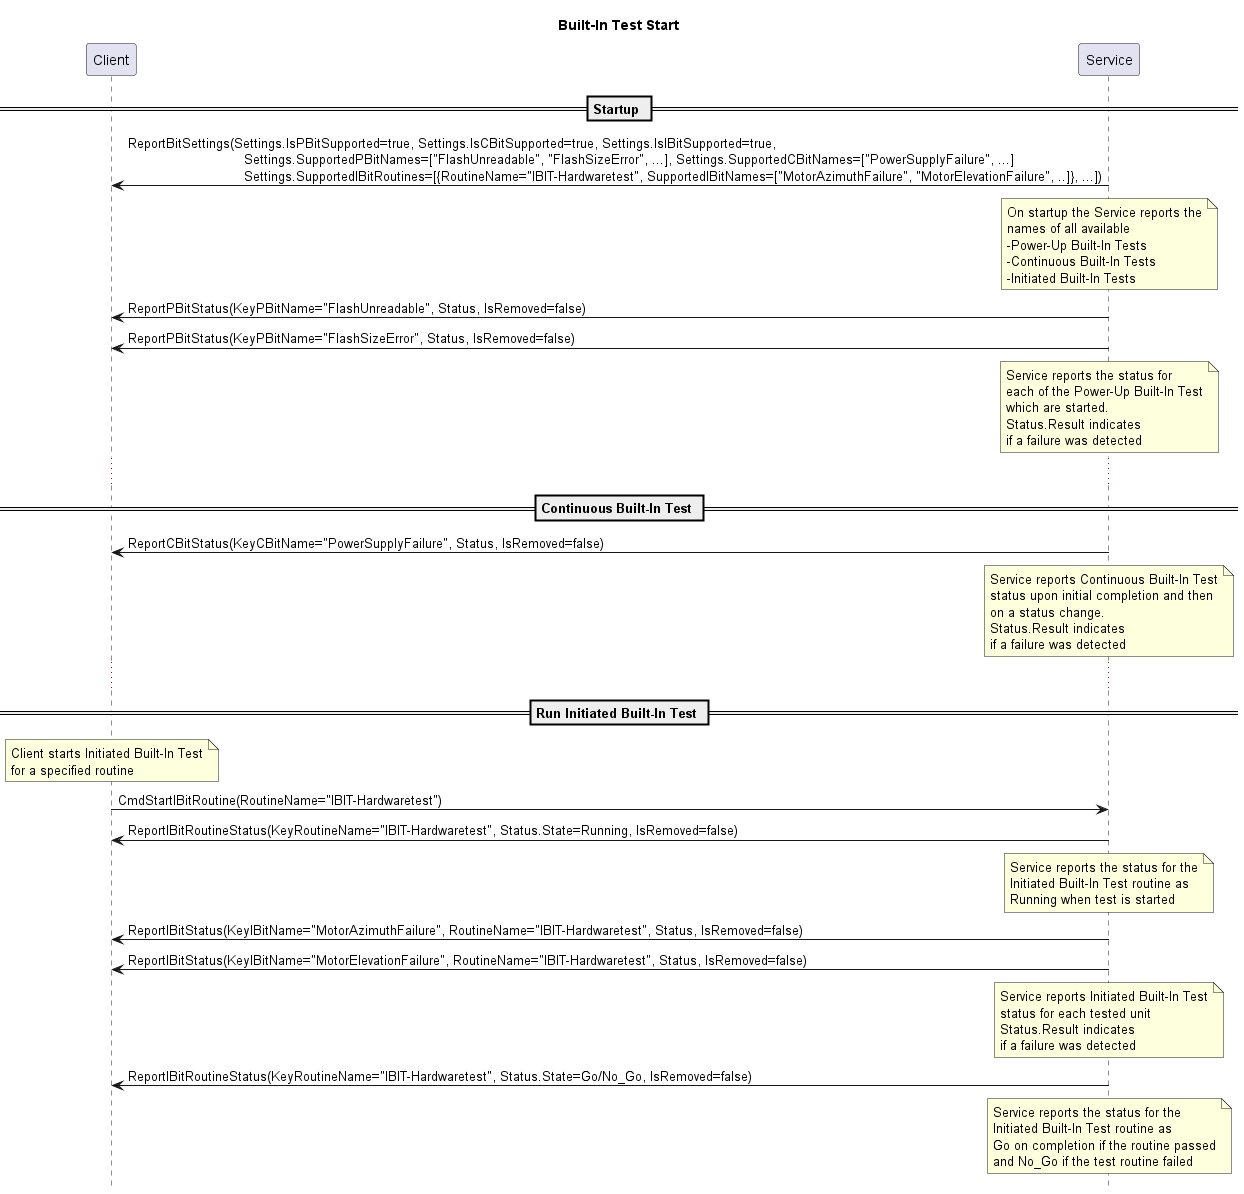
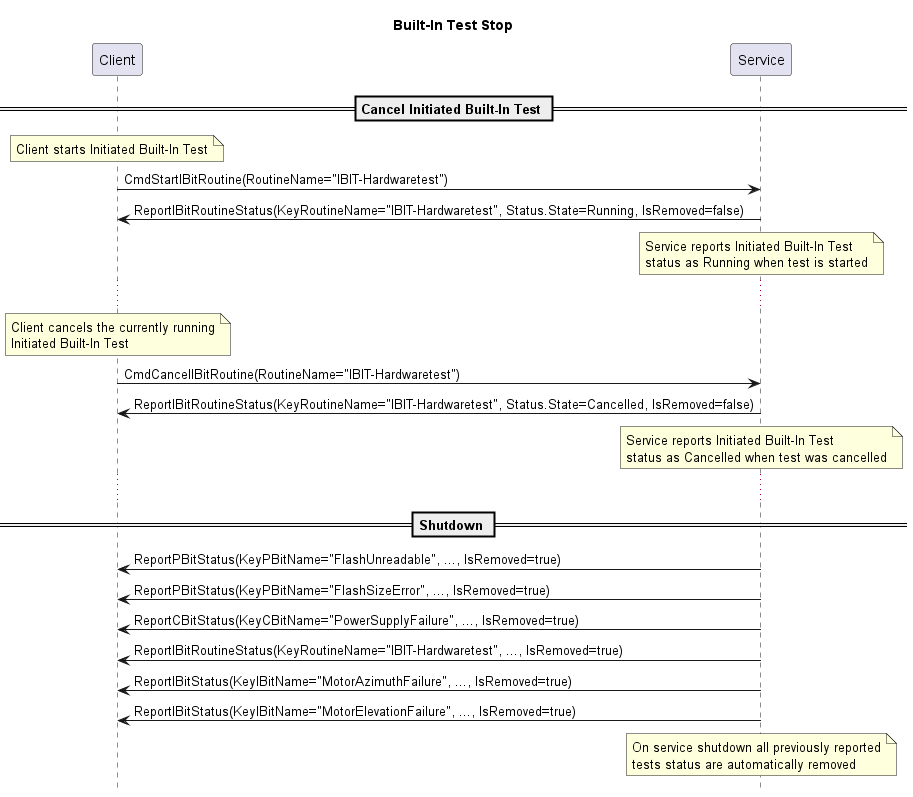
Client and Service classes:
Operations:
Description:
Types used by the BITE (Built-In Test Equipment) Control Service and Client. A BITE (Built-In Test Equipment) Control service is used to control the Built-In Test subsystem.
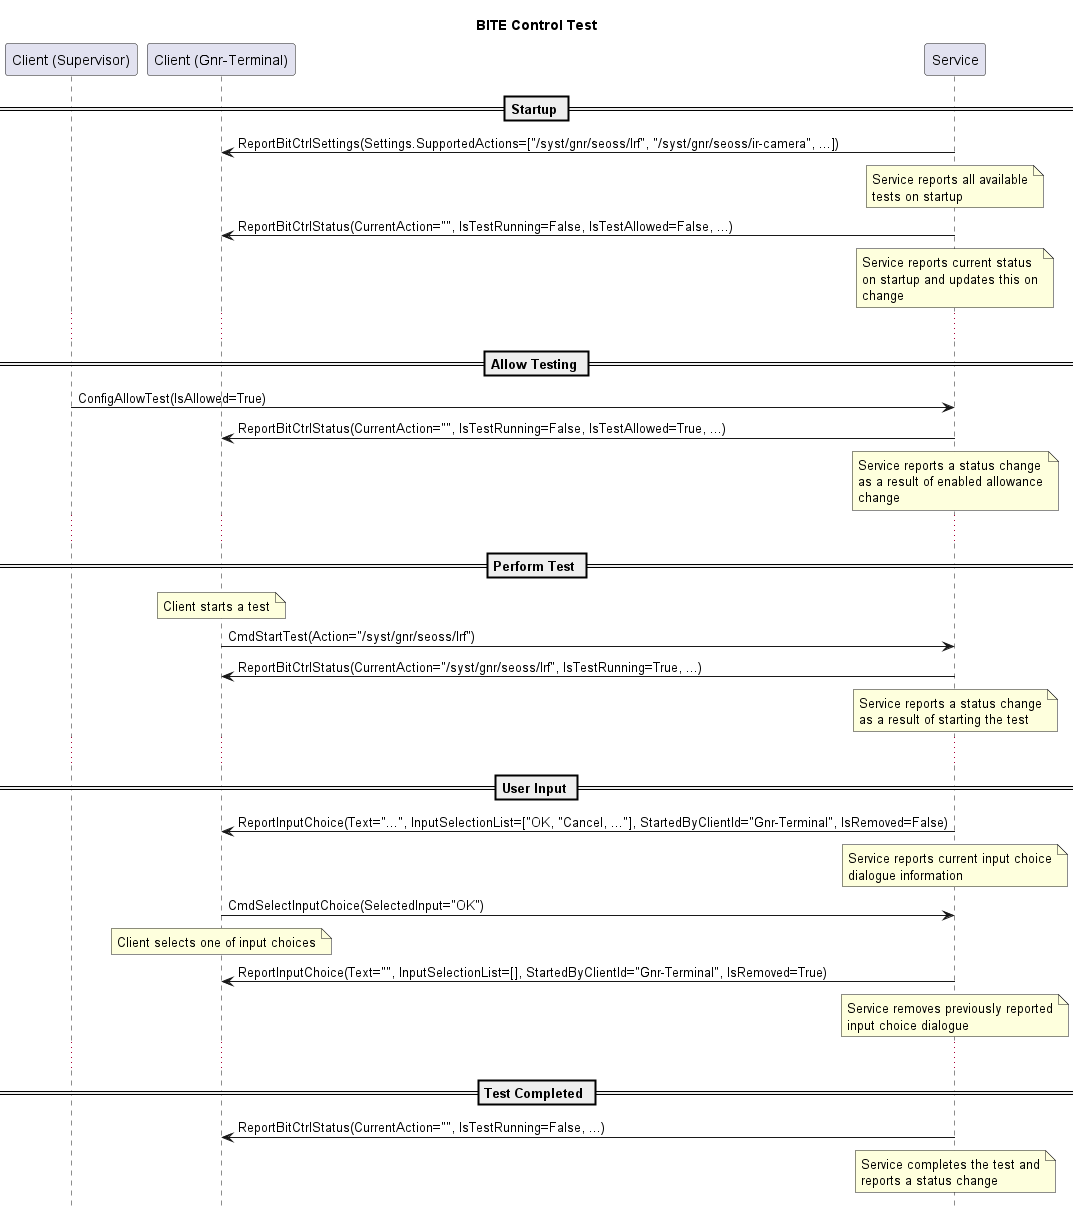
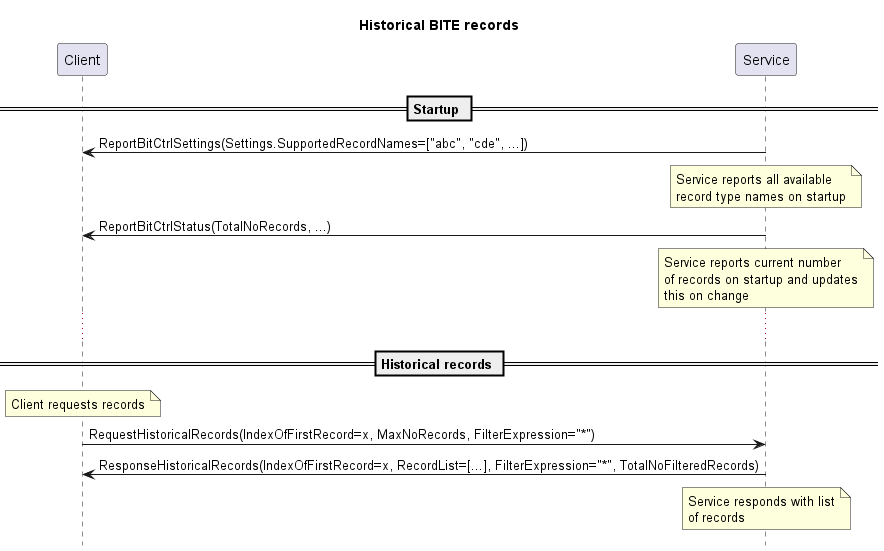
Client and Service classes:
Operations:
Description:
Types used by the Camera Service. A Camera service is used to control the various image controls of a camera.
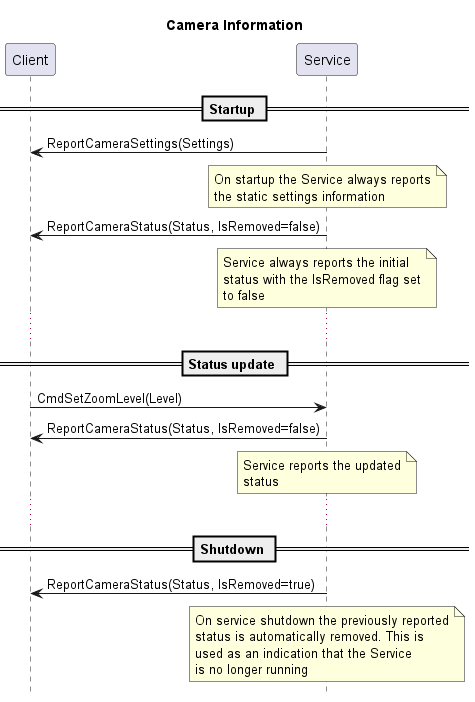
Client and Service classes:
Operations:
Description:
A camera manager to dynamically create, update and delete cameras.
Client and Service classes:
Operations:
Description:
Types used by the coordinate frame service and client. Interfaces used by the coordinate frame service and client. The service can be used to manage positions, attitudes and motion across different reference frames. It also enables aligning a component's line of sight with a target.
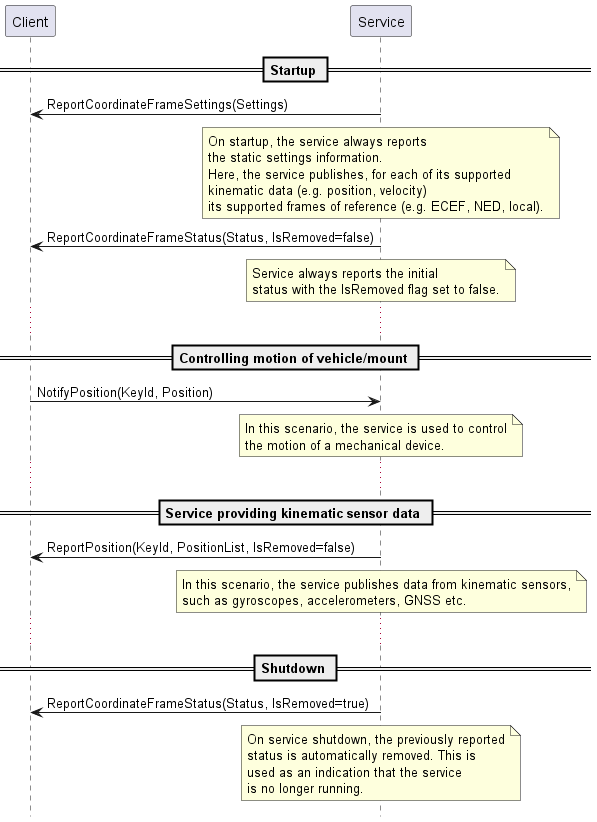
Client and Service classes:
Operations:
Description:
Types used by the Device Service and Client. A device service represents a resource or application. It can be used to report general information such as version info and device mode.
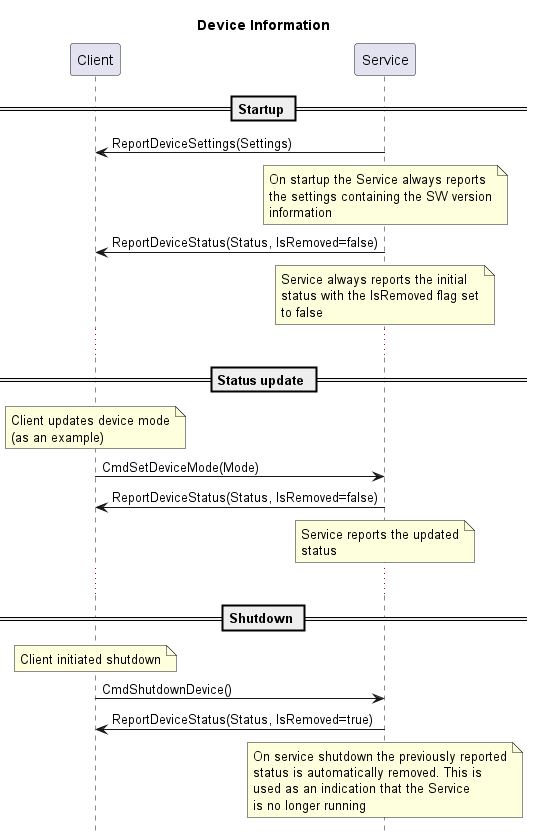
Client and Service classes:
Operations:
Description:
Types used by the dialogue service and client. A dialogue service is used to control user dialogues and other text-based messages (e.g. used for logging).
Client and Service classes:
Operations:
Client and Service classes:
Operations:
Description:
Interfaces and types used by the FileTransfer Service and Client. Interfaces and types used by the FileTransfer Service and Client.
Client and Service classes:
Operations:
Description:
Types used by the GenericInputOutput Service and Client A generic input output service represents any IO interface. It can be used to report any information about the IO interface.
Client and Service classes:
Operations:
Description:
Types used by the Coord Input Service. A Coord Input service represents an input device such as a touch screen or a mouse which can generate input coordinates (2D pixel points) representing a mouse button or touch screen press.
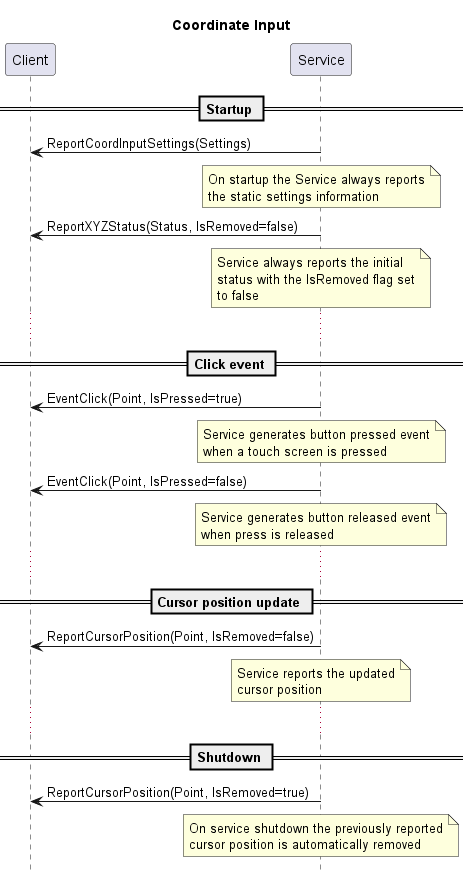
Client and Service classes:
Operations:
Description:
Types used for input devices, for example Joystick axis and buttons. A HID Display service can be used to represent an HID Display.
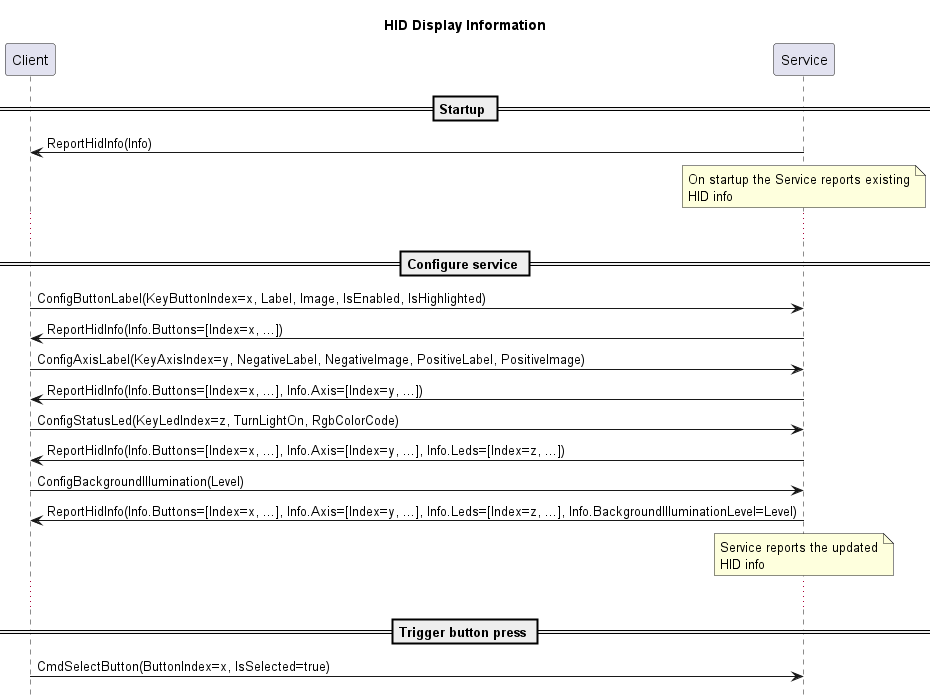
Client and Service classes:
Operations:
Description:
Types used for input devices, for example Joystick axis and buttons. Interfaces used to handle Joysticks. A HID Joystick service is used to represent inputs from a Joystick.
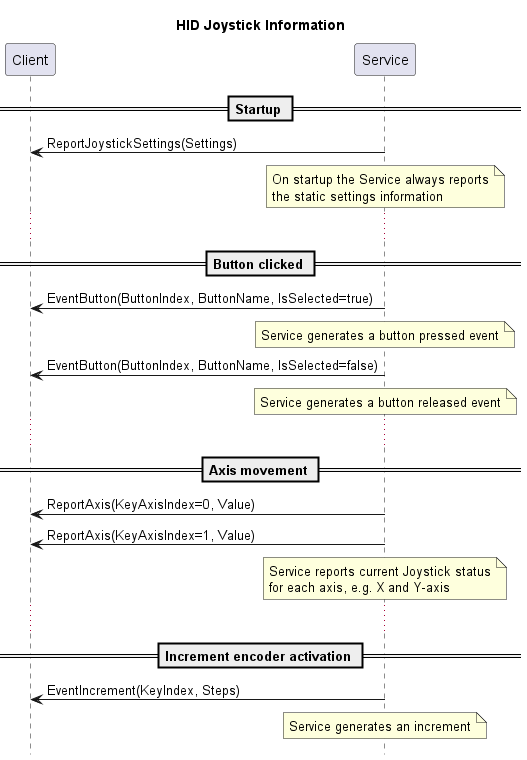
Client and Service classes:
Operations:
Description:
Data types used by the HID Manager. Interfaces used by the HID Manager.
Client and Service classes:
Operations:
Description:
Data types used by the HMI application control service. An HMI application control service manages external application views for the HMI.
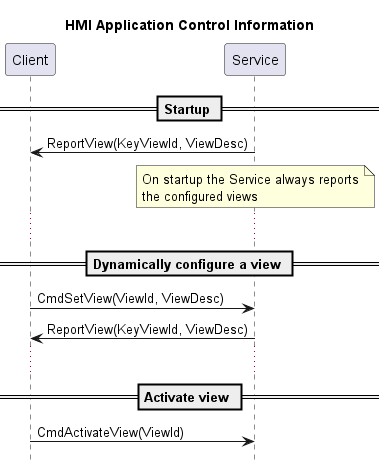
Client and Service classes:
Operations:
Description:
Interfaces used by the ImageComposer Service and Client. An Image Composer service represents is used to configure view ports for video streams.
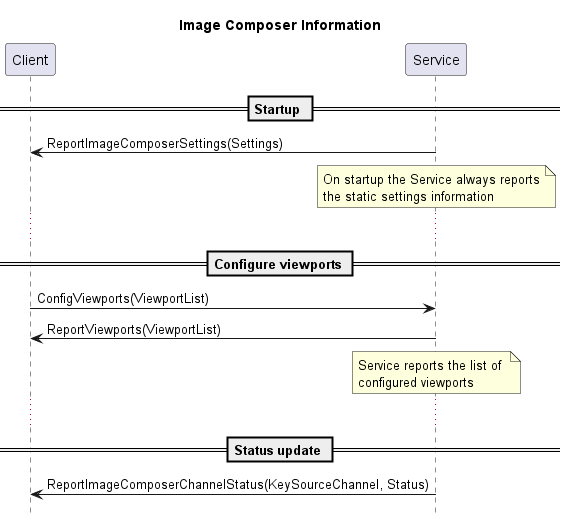
Client and Service classes:
Operations:
Description:
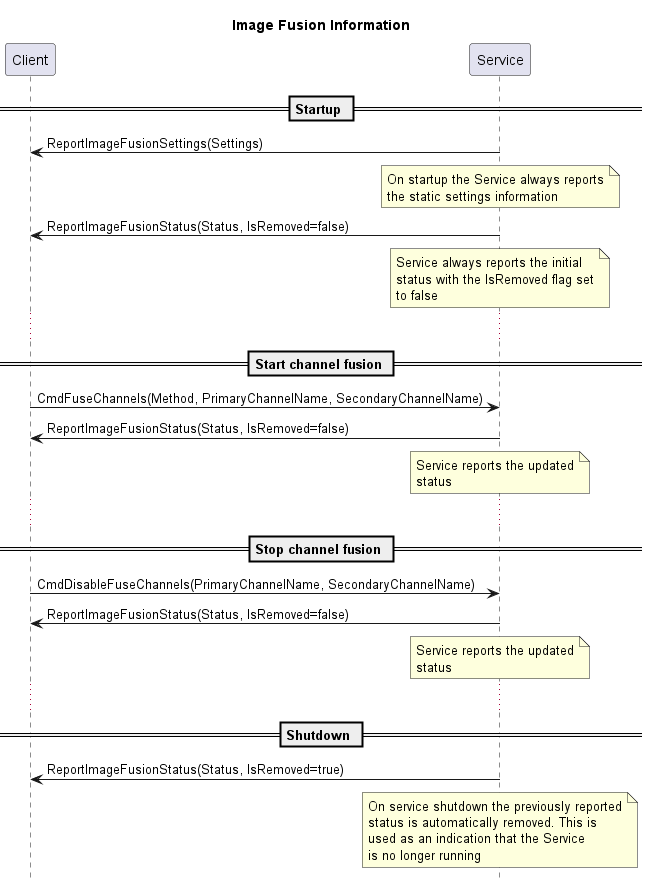
Interfaces used by the ImageFusion Service and Client. An Image Fusion service is used to blend two video channels together.
Client and Service classes:
Operations:
Description:
Types used by the image processing service and client. Interfaces used by image processing devices.
Client and Service classes:
Operations:
Description:
Types used by the kinematic chain service and client. Interfaces used by the kinematic chain service and client.
Client and Service classes:
Operations:
Description:
Types used by the language manager service and client. Interfaces used by the language manager service and client.
Client and Service classes:
Operations:
Description:
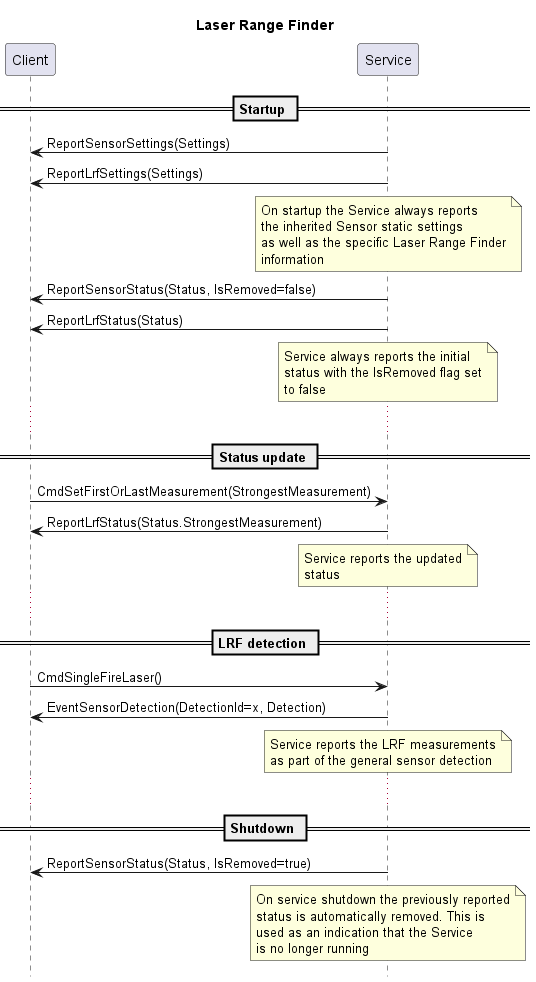
Interfaces used to handle Laser Range Finder. A Laser Range Finder (LRF) service represents a Laser Range Finder. It extends a Sensor service with information specific to a Laser Range Finder (LRF) Sensor.
Client and Service classes:
Operations:
Description:
Types used by the Logging Service and Client. A logging service represents a resource or application. It can be used to send or request log messages and change the runtime log level.
Client and Service classes:
Operations:
Description:
Types used by the manipulator service and client. Interfaces used by the manipulator service and client.
Client and Service classes:
Operations:
Description:
Types used by the Meteorological Sensor Service. Interfaces used by the Meteorological Sensor Service and Client.
Client and Service classes:
Operations:
Description:
Types used by the mission control service and client. Interfaces used by the mission control service and client.
Client and Service classes:
Operations:
Description:
Types used by the Mount Service. Interfaces used by the Mount Service and Client.
Client and Service classes:
Operations:
Description:
Types used by the Mount Service. Interfaces used by the Mount Service and Client.
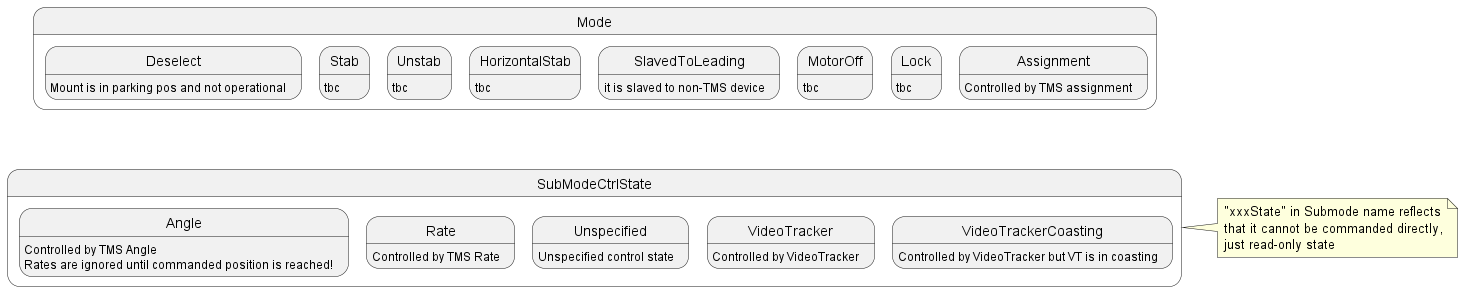
The following conventions may apply for the given operations:
Client and Service classes:
Operations:
Description:
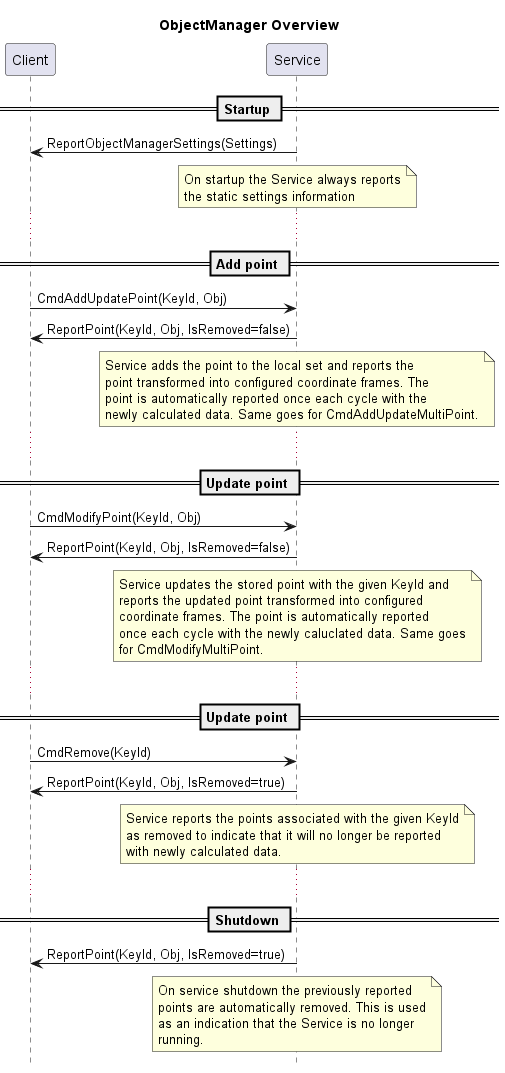
Types used by the Object Manager Service/Client. Interfaces used by the ObjectManager Service and Client.
Client and Service classes:
Operations:
Description:
Types used by the Overlay Ctrl Client and Service. An Overlay Control service is used to handle graphical overlays.
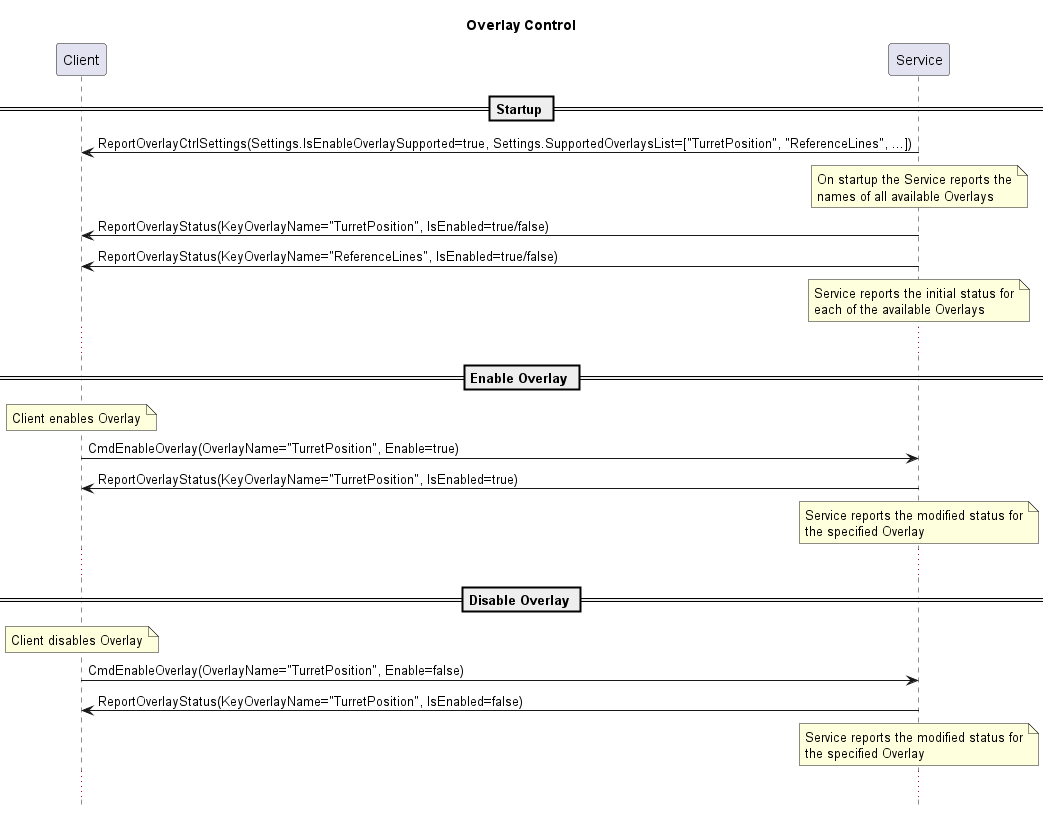
Client and Service classes:
Operations:
Description:
Interfaces and types used by the Recording Control Service and Client. Interfaces and types used by the Recording Control Service and Client.
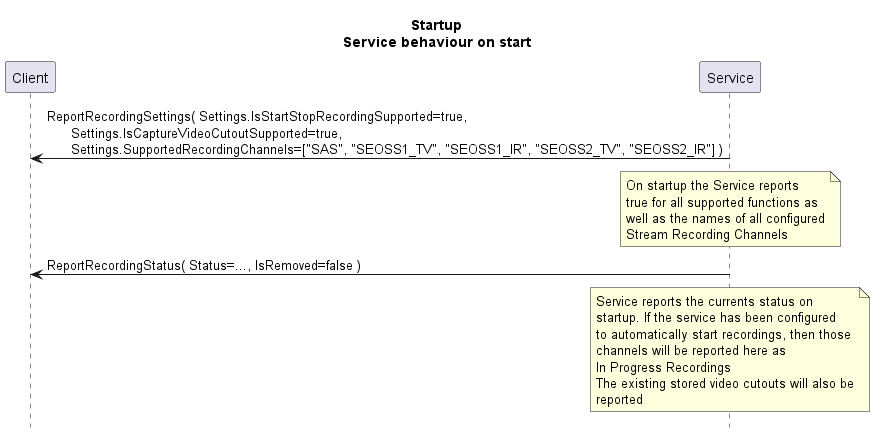
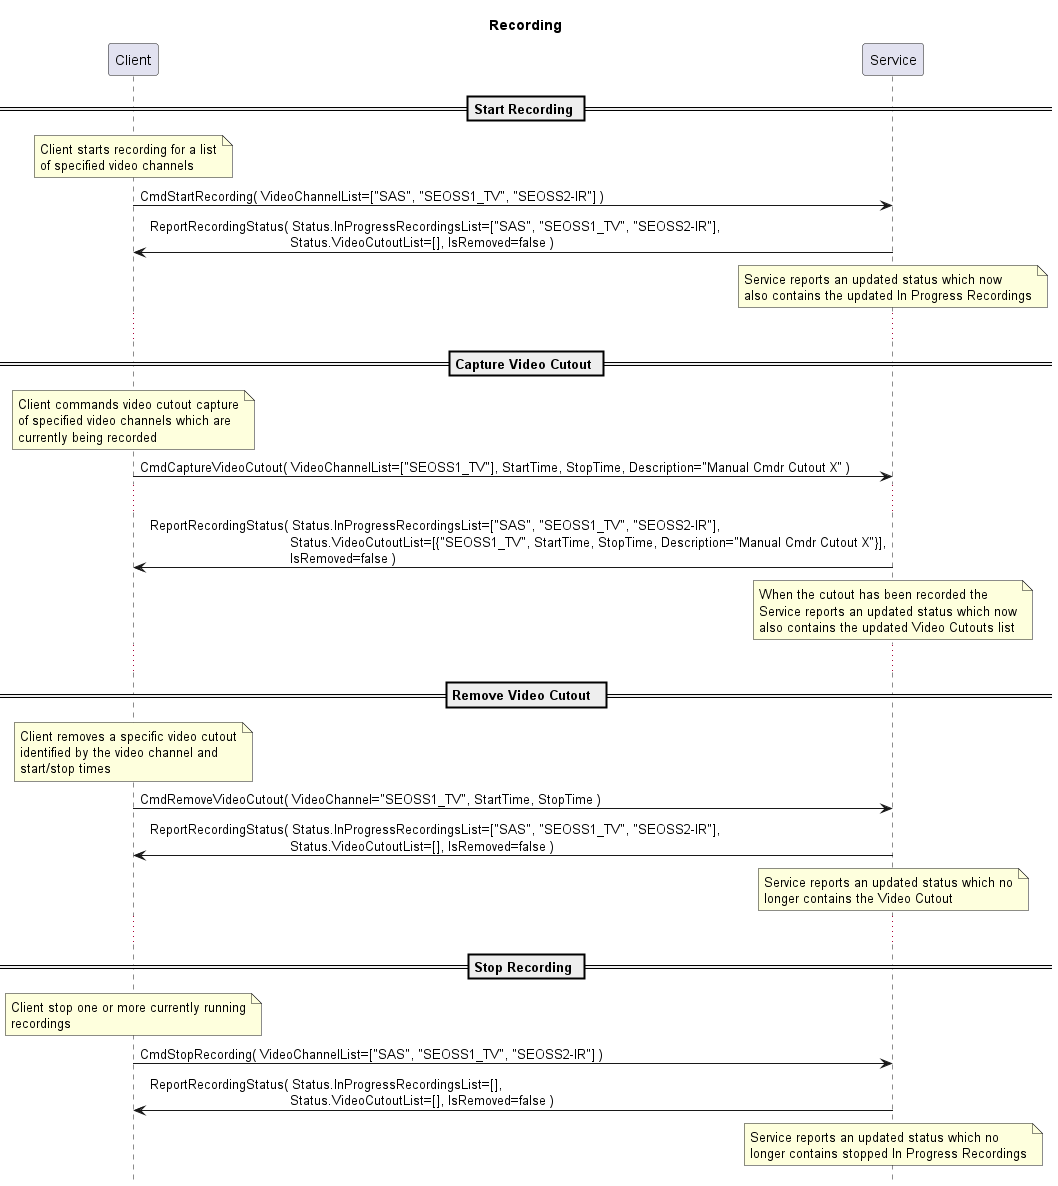
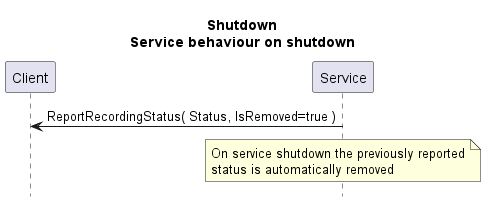
Client and Service classes:
Operations:
Description:
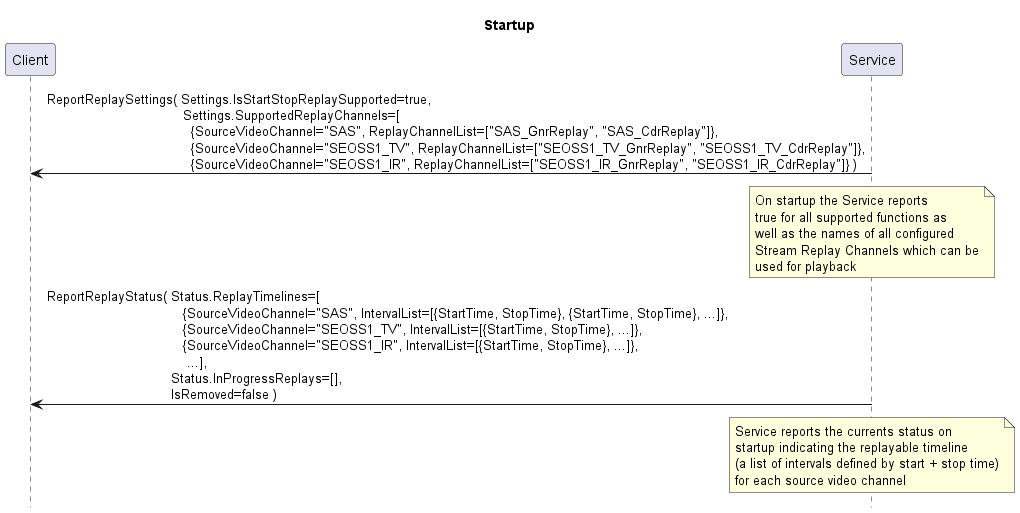
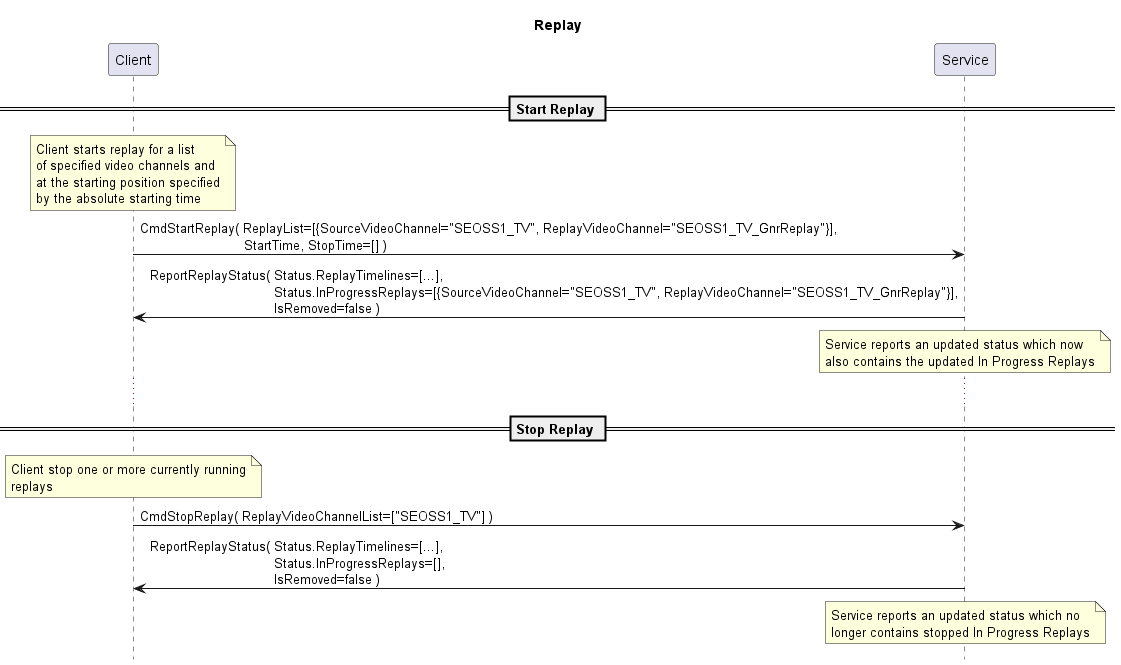
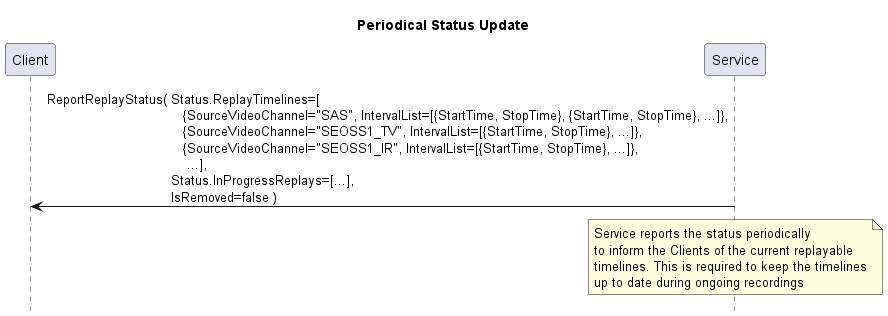
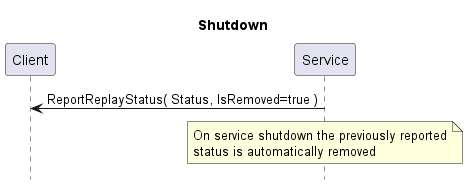
Interfaces and types used by the Replay Control Service and Client. Interfaces and types used by the Replay Control Service and Client.
Client and Service classes:
Operations:
Description:
Types used by the ScanCtrl Service/Client. Interfaces used by the Scan Control Service and Client.
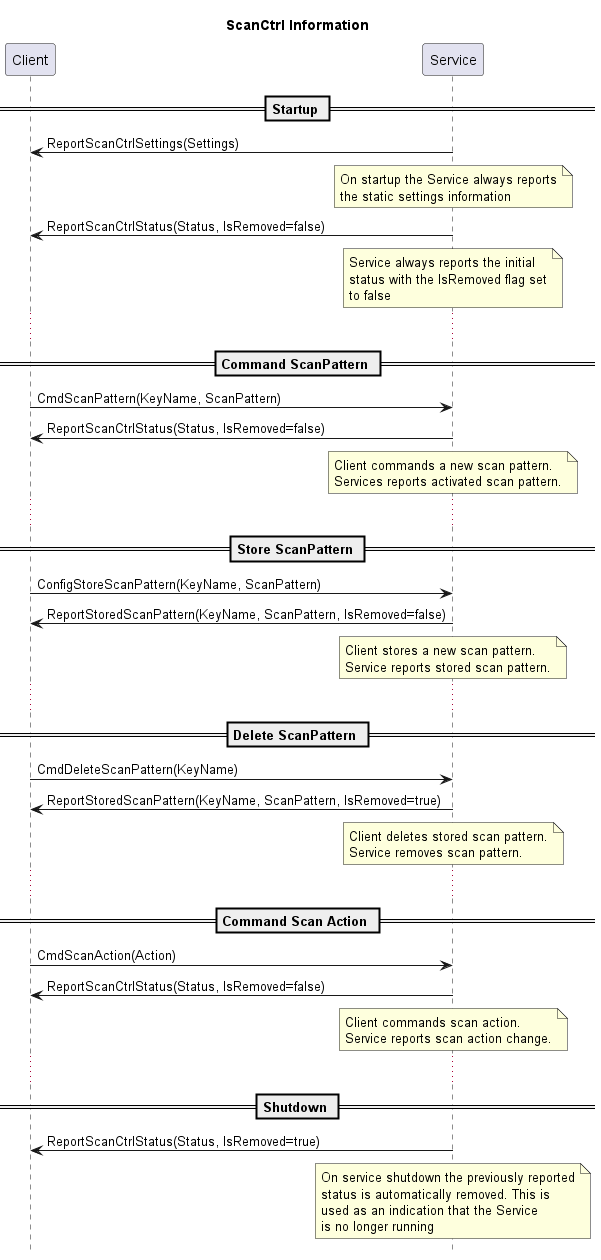
Client and Service classes:
Operations:
Description:
Types used by the Sector Selection Service. A Sector Selection service is used to select sectors from an HMI.
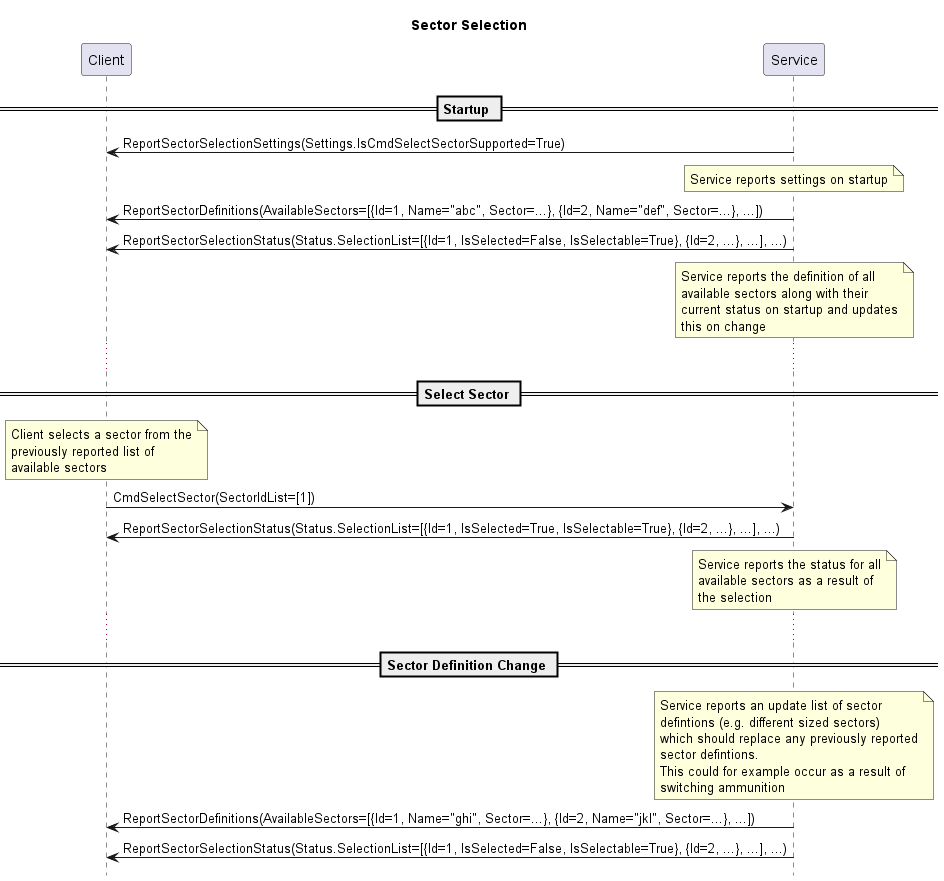
Client and Service classes:
Operations:
Description:
Interfaces used to handle a sensor. The sensor interface contains general information common to different tactical sensors.
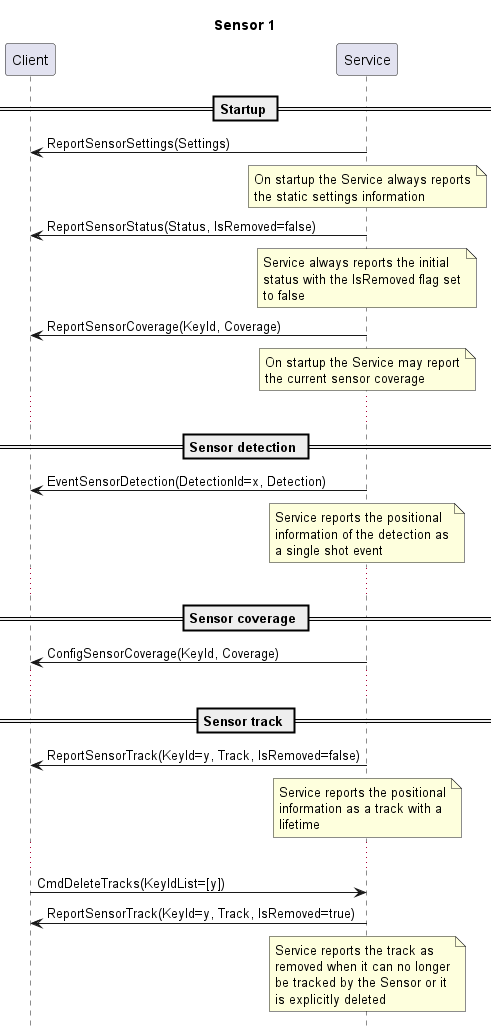
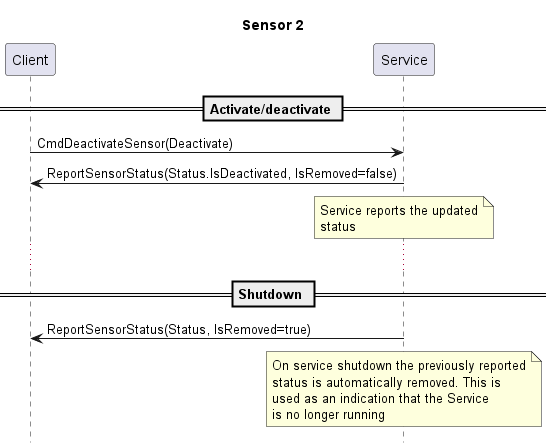
Client and Service classes:
Operations:
Description:
Types used by the signal generator service and client. Interfaces used by the signal generator service and client.
Client and Service classes:
Operations:
Description:
Types used by the signal processing service and client. Interfaces used by signal processing devices.
Client and Service classes:
Operations:
Description:
Types used by the teleoperation service and client. Interfaces used by the teleoperation service and client.
Client and Service classes:
Operations:
Description:
Types used by the Terminal Control interfaces. Interfaces used by the Terminal Control Service and Client. The Terminal Control Service can be used to control a Terminal host node, by commanding it to do things such as changing the display brightness.
Client and Service classes:
Operations:
Description:
Types used by the time manager service and client. Interfaces used by a time service and client.
Client and Service classes:
Operations:
Description:
Types used by the Video Manager Service. Interfaces used by the Video Manager Service and Client. The Video Manager handles the switching between Cameras (e.g. TV/IR) and coupling the Field of View.
Client and Service classes:
Operations:
Description:
Types used by the Video Metadata Interface. Interfaces used by the video metadata service and client.
Client and Service classes:
Operations:
Description:
Types used by the Video Object Export Service and Client. Interfaces used by the Video Object Export Service and Client.
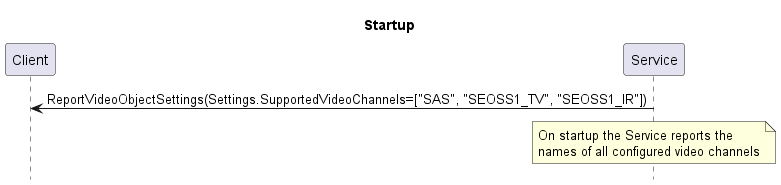
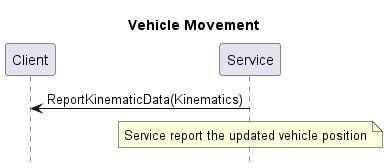
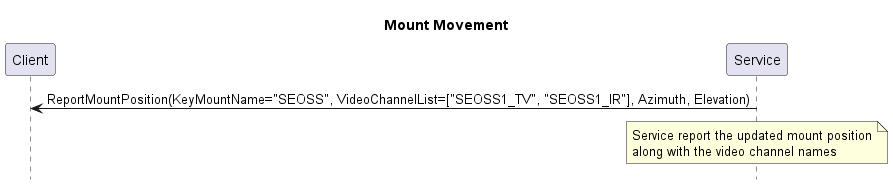
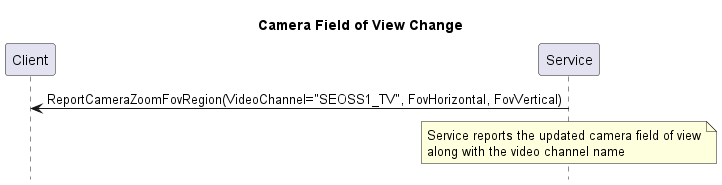
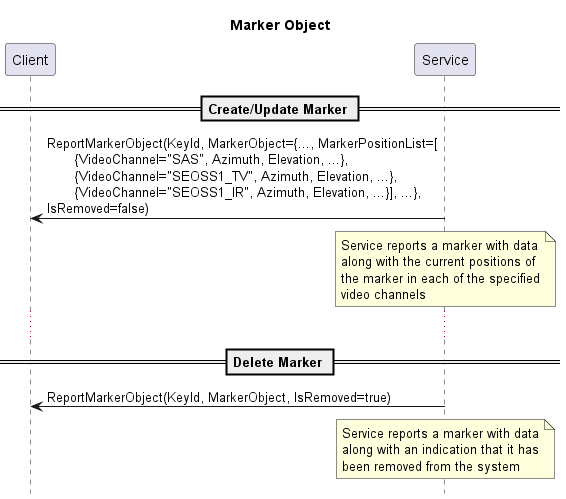
Client and Service classes:
Operations:
Description:
Interfaces used by the Automatic Track Recognition (ATR) Service and Client. This tracking mode establishes tracks automatically based on expected object characteristics.
Client and Service classes:
Operations:
Description:
Interfaces used by the Multi-Mode Tracker Service and Client.
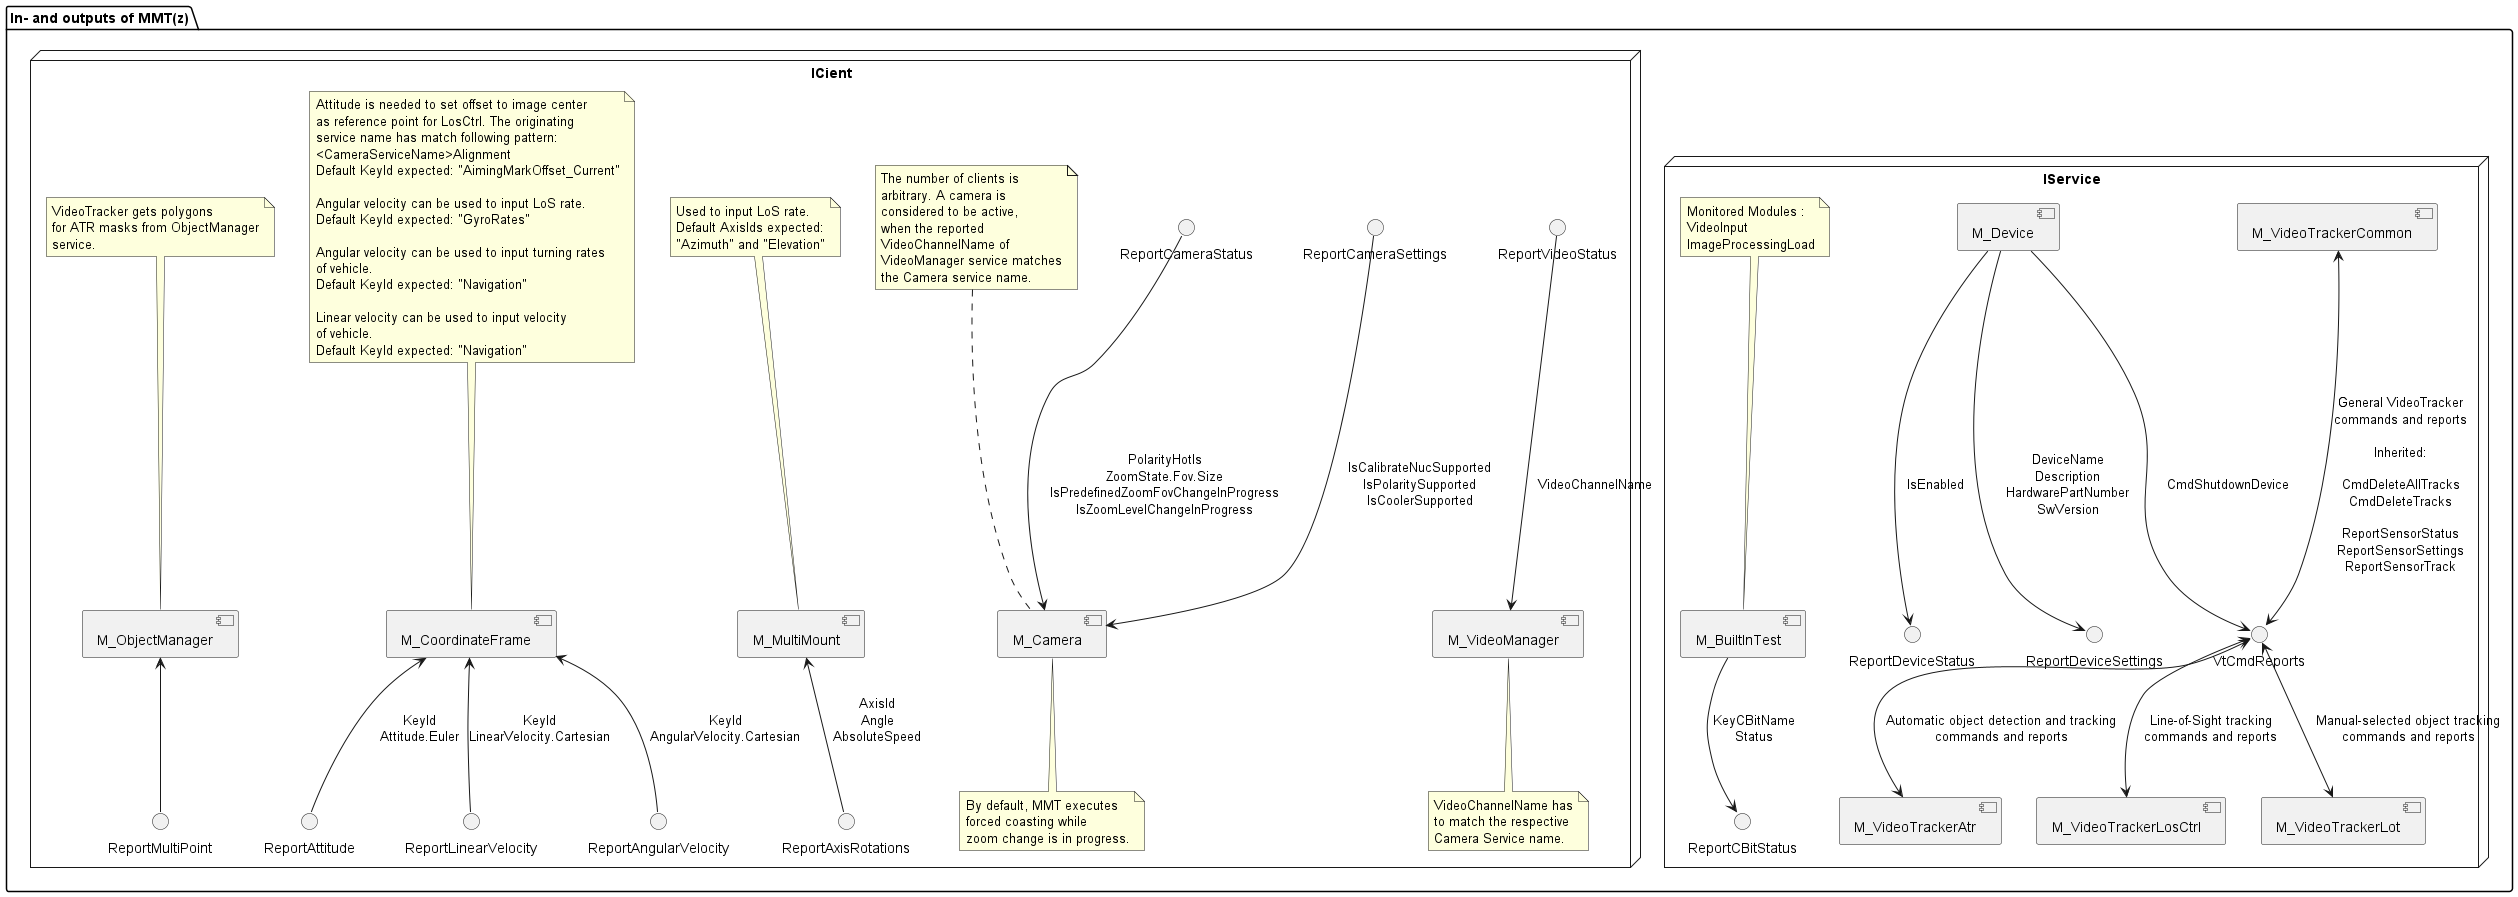
Client and Service classes:
Operations:
Description:
Interfaces used by the Line-of-Sight Control (LOS) Service and Client. VideoTracker LOS-Control module holds the Line-of-Sight onto objects for Line-of-Sight tracking. The units of this interface are angular. The LOS-Control module needs information from the system to perform LOS-Control tasks, see M_VideoTrackerCommon interface description.
Client and Service classes:
Operations:
Description:
Interfaces used by the Lock-On Tracking (LoT) Service and Client. This tracking mode is active for objects, that are locked-on by the operator.
Client and Service classes:
Operations:
Description:
Types used by the watchdog service and client. Interfaces used by the watchdog service and client.
 1.9.1